DarkDriving: A Real-World Day and Night Aligned Dataset for Autonomous Driving
Project page for DarkDriving, accepted at ICRA 2026.
*Equal contribution
Abstract
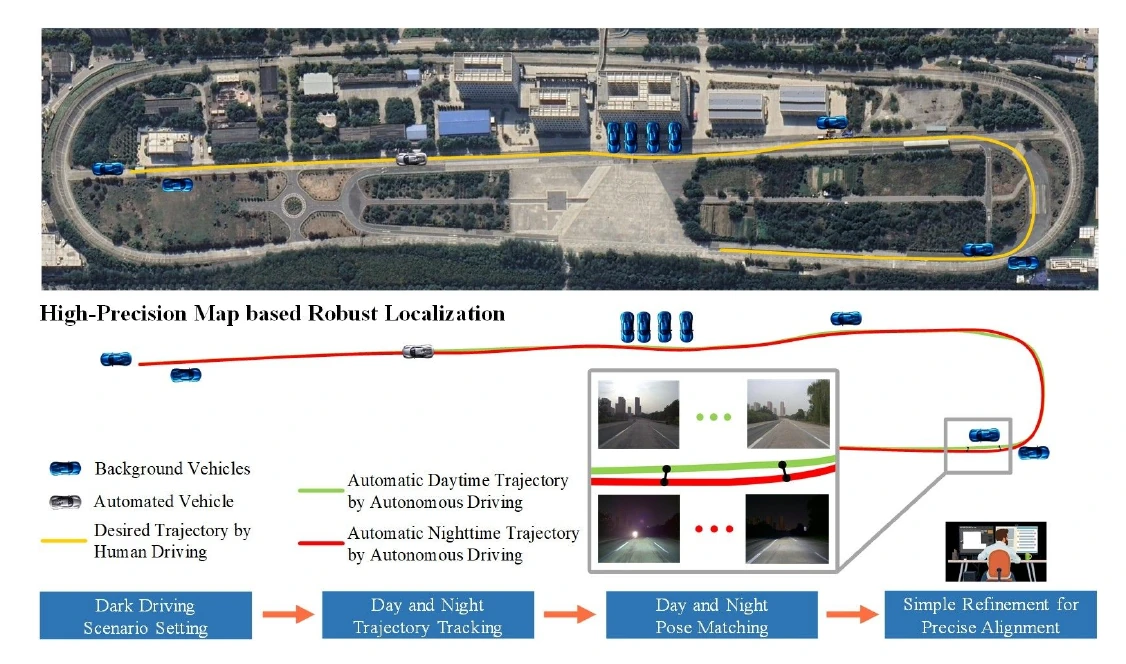
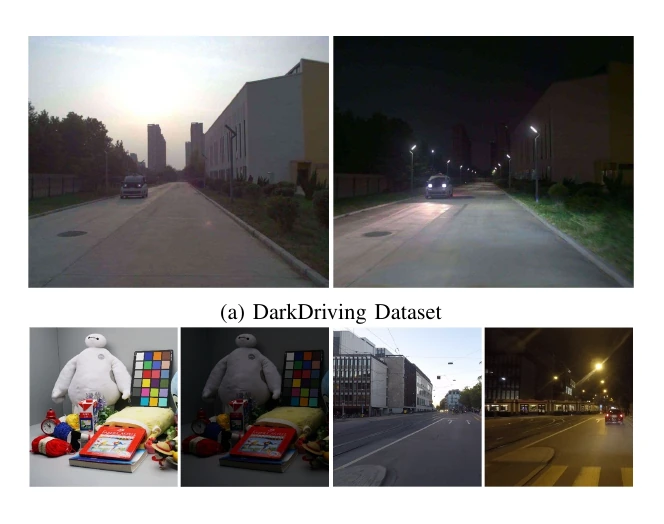
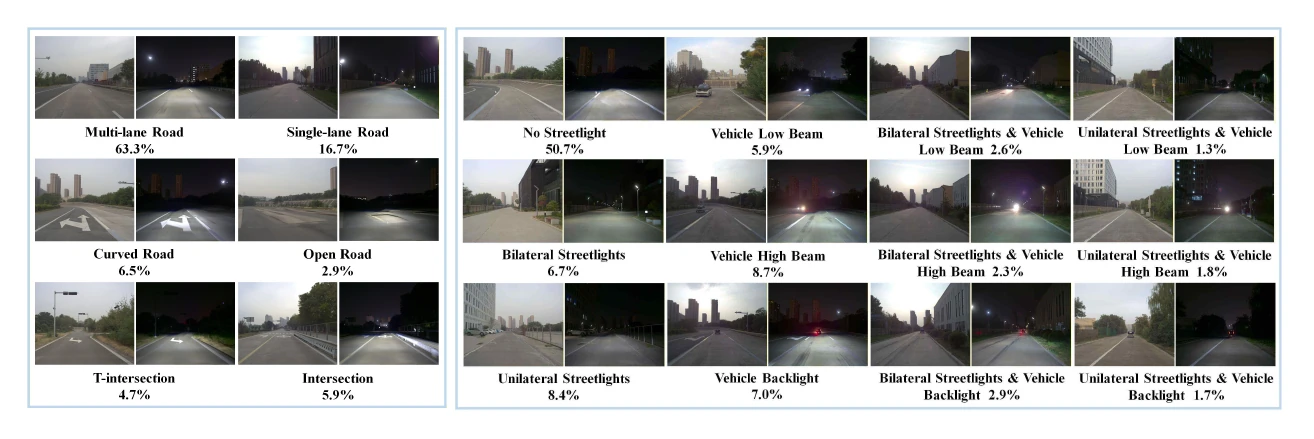
DarkDriving is a real-world benchmark for low-light autonomous driving. It contains 9,538 day-night image pairs with centimeter-level alignment in both location and scene content, captured on a 69-acre closed driving test field and annotated with 2D object boxes.
Dataset
Results
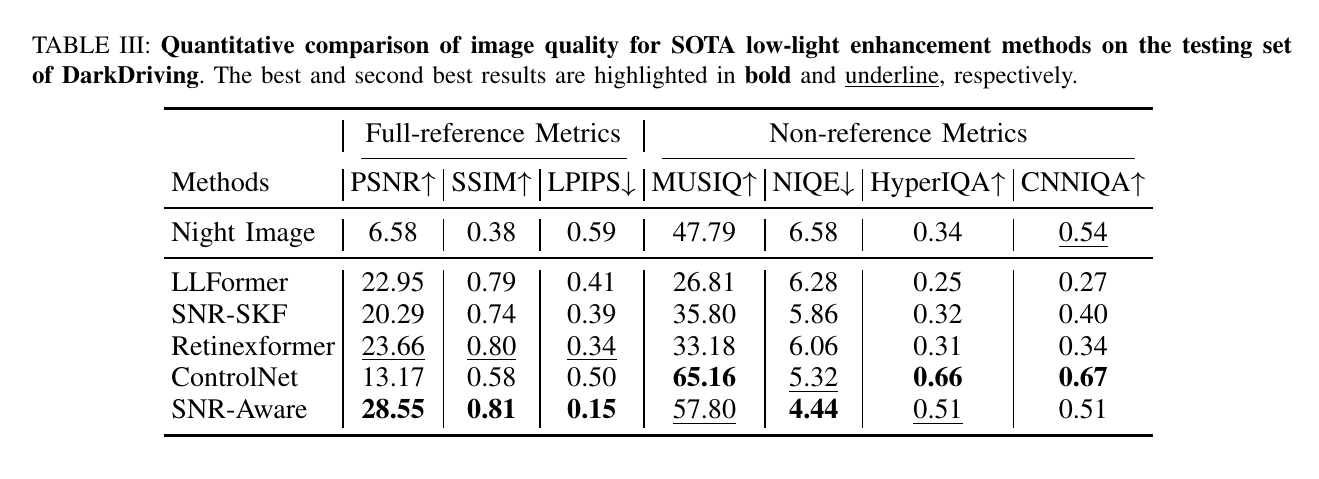
DarkDriving enables supervised enhancement with real paired daytime targets. The main comparison summarizes both full-reference and no-reference image-quality metrics across representative low-light enhancement methods.
BibTeX
@inproceedings{wang2026darkdriving,
  title     = {DarkDriving: A Real-World Day and Night Aligned Dataset for Autonomous Driving in the Dark Environment},
  author    = {Wang, Wuqi and Yang, Haochen and Li, Baolu and Sun, Jiaqi and Zhao, Xiangmo and Xu, Zhigang and Guo, Qing and Min, Haigen and Zhang, Tianyun and Yu, Hongkai},
  booktitle = {IEEE International Conference on Robotics and Automation},
  year      = {2026}
}